Perceive
A forward-facing camera in the handle captures the scene in front of the user, well beyond the reach of the cane tip.
- Continuous view of the path ahead
- Sees obstacles before the cane touches them
- Designed for indoor and outdoor environments
Technology
NextGuide brings the perception and decision-making of intelligent machines into the handle of a white cane, and communicates what it understands through touch.
The loop
NextGuide continuously runs a closed loop from perception to guidance, entirely inside the handle.
A forward-facing camera in the handle captures the scene in front of the user, well beyond the reach of the cane tip.
Multimodal AI turns raw images into an understanding of the scene: what is free space, what is in the way, and what matters for getting somewhere.
A learned navigation model, built on principles from robotics, decides on a safe direction through the scene and updates it continuously as the user moves.
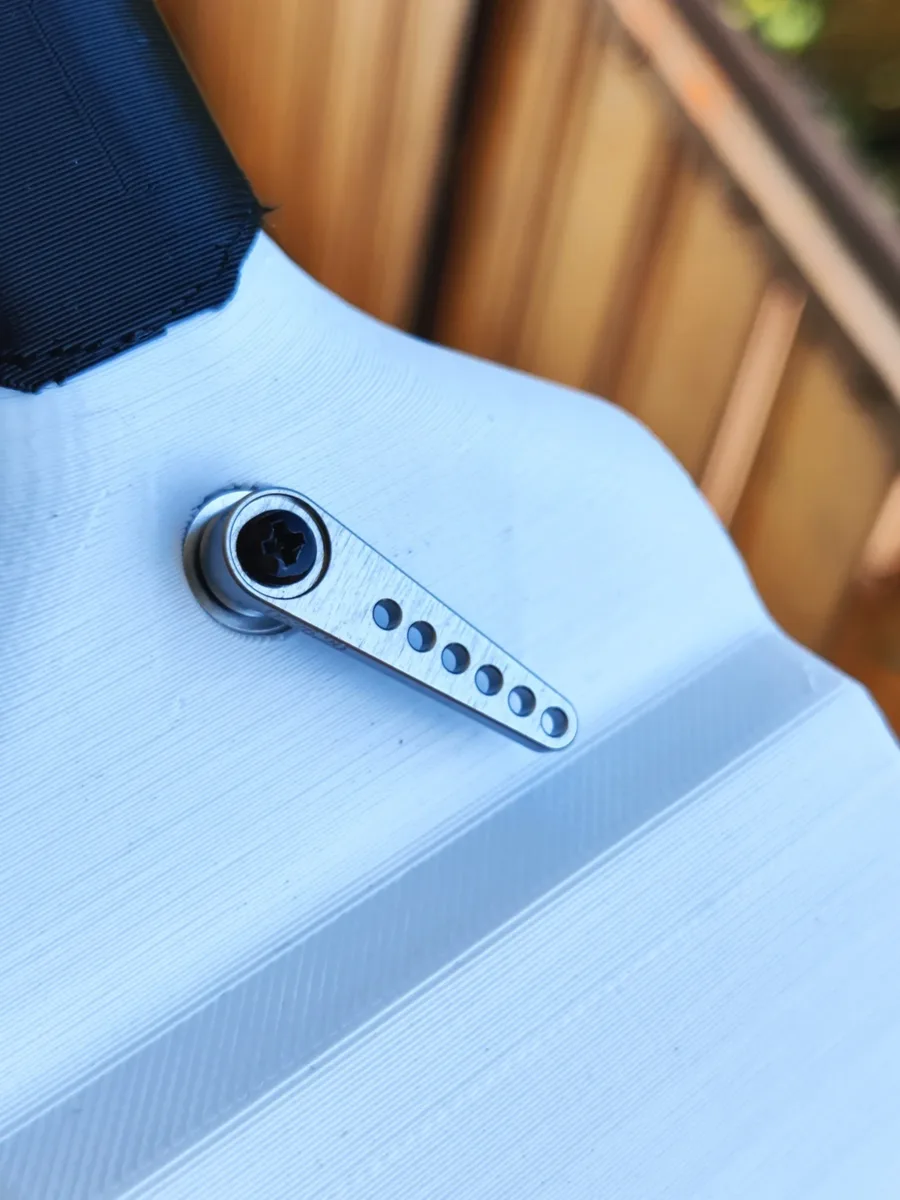
The plan becomes touch. A tactile pointer under the thumb shows the direction to walk, and distinct vibration patterns signal what is ahead.
Demos
Point-of-view footage from earlier prototypes, recorded on real paths and in ETH buildings.
Principles
On-device by design
All AI runs on a dedicated processor inside the handle. No cloud, no smartphone and no network connection are needed, so guidance stays fast and camera images never leave the device.
Human in the loop
NextGuide suggests a direction and lets the user feel it. It never takes over. The cane remains a cane, so users keep the technique and feedback they already rely on.
Hardware
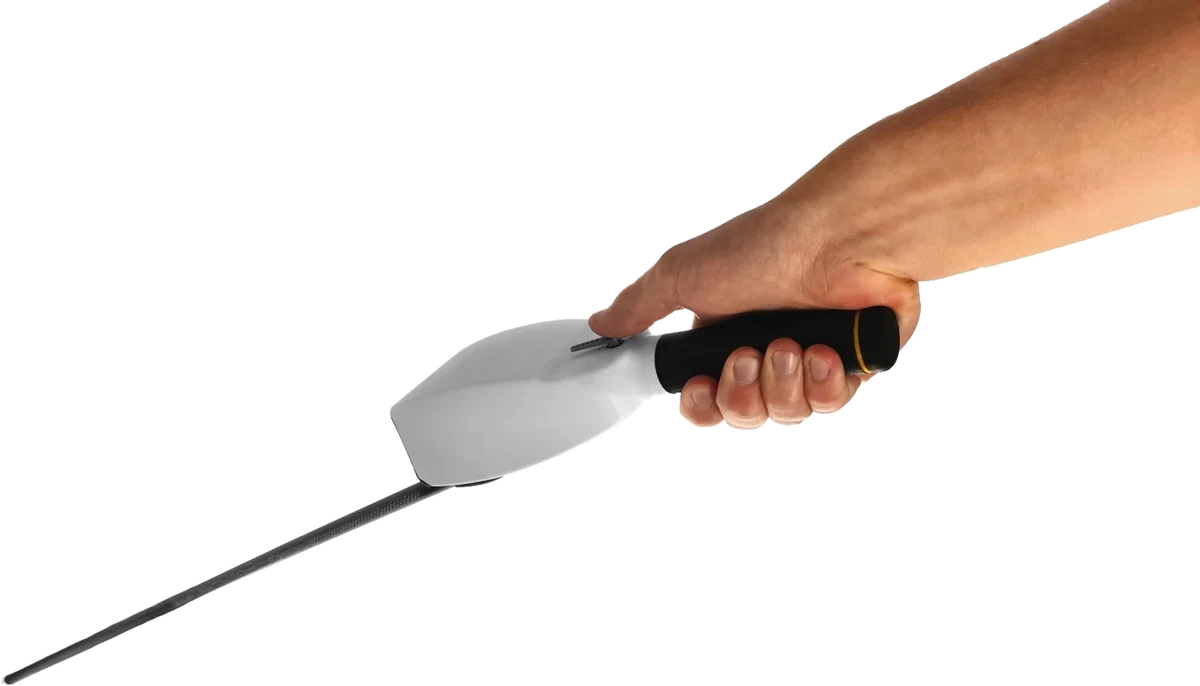
Camera, AI processor, haptics and battery in one ergonomic grip.
Rotates under the thumb to show the free path.
Origins
NextGuide grew out of engineering work at ETH Zurich and was presented as part of CYBATHLON at REHACARE. Today it is a working research prototype.
The next stage is turning the prototype into a certified medical device, built to the standards of safety-critical engineering.
We’d love to talk with investors, press and partners.